Multi-DOF Arm (WIP)
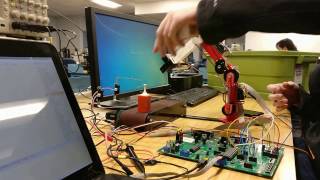
After finishing the Unified Robotics III undergrad course at WPI, I felt the need to further experiment and learn about open-loop kinematic chains. This course inspired me to build from scratch a bigger, better, and more dangerous arm. The intention of this arm was to be able to lift objects of a least 5 lbs in the extents of the workspace. Additionally have to ability to reach 3 feet from the base of the robot.

Above is a render of the initial design of the first 3 degrees of freedom. The base joint is using a RS775 connected to a PG71 planetary gearbox. The other two joints are using a bag motor connected to a 3-stage 300:1 versa v2 planetary gearbox each. Each axis used a 5k Ohm 3 turn potentiometer for absolute positioning.
The joints were machined out of 6061 Aluminum on HAAS CNC machines here at WPI.
20170225_031649 20170225_031701 20170225_031632 20170303_222709 20170304_033230 20170225_031614 20170304_033239 20170304_033247 20170304_033226 20170315_064321 20170315_064328 20170315_064421






Comments